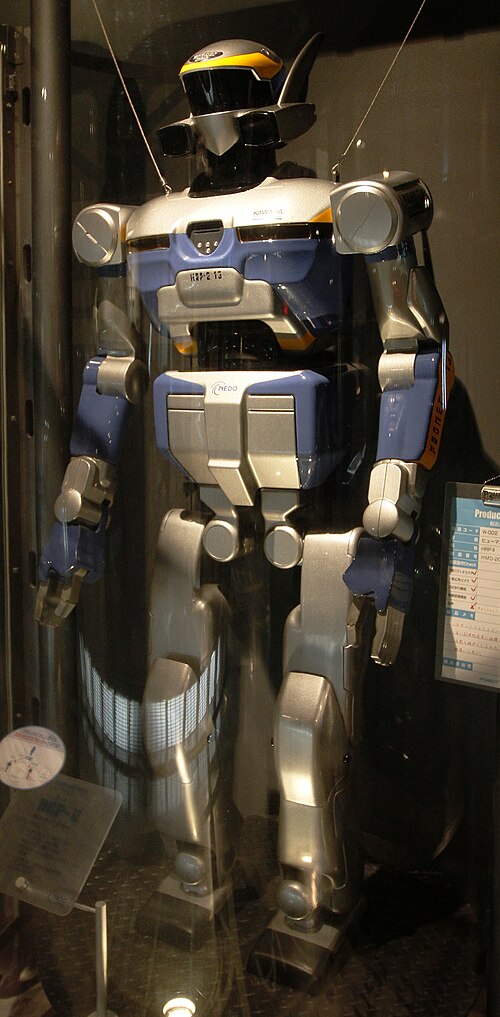
HRP-2
AIST / Kawada Industries · Japan · unveiled in 2002
prototype
HRP-2 is a research humanoid developed jointly by AIST and Kawada Industries. It can walk on two legs and get up from the ground after a fall.
Applications
Data
| height | 1,54 m [1] [2] |
|---|---|
| weight | 58 kg [1] [2] |
| degrees of freedom | 30 [1] [2] |
Sources
- IEEE Robots Guide – HRP-2
- AIST – announcement of HRP-5P and the history of the series, 27. 9. 2018
- Kawada Robotics – research platforms HRP-2, HRP-3 and HRP-4
In the History of robots
- 2003 – HRP-2 as a research platform