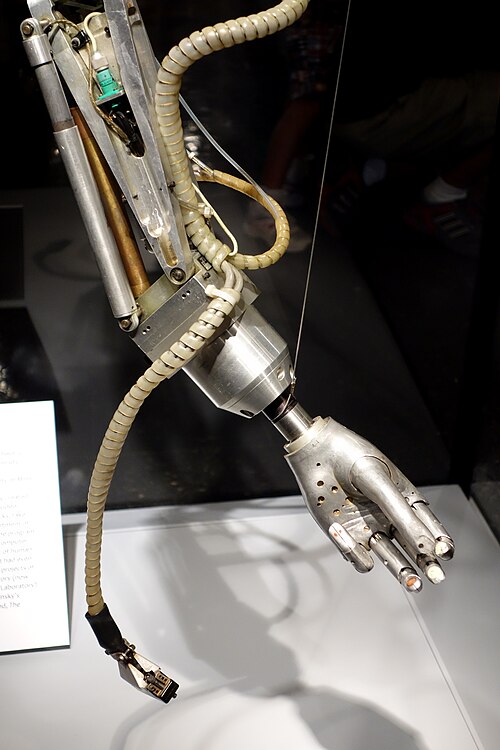
around 1968
Minsky's tentacle arm
United States · Robotics
Around 1968 at MIT, Marvin Minsky developed a twelve-jointed hydraulic arm that moved like an octopus tentacle and could reach around obstacles. It was controlled by a DEC PDP-6 computer. [1][2][3][4]
Sources